Standard Bots 访谈:自称美国最大的 AI 原生工业机器人厂商,刚以 10 亿美元估值完成由 General Catalyst 与 RoboStrategy 领投的 2 亿美元 C 轮,客户含 NASA、Amazon 与 Lockheed Martin。其经验是把模型职责收窄——感知(定位与识别零件)交给在超过十亿张图上训练的零样本系统,运动与单元逻辑仍用传统编程;最大模型只有低数十亿
Building AI for Reliable Execution: Lessons From Industrial Robotics
评分 69
导读
这期访谈的对象是 Standard Bots——一家自称「美国最大的 AI 原生工业机器人制造商」的公司,其机械臂用于机床上下料、焊接与装配。文中给出的商业事实是:它刚完成 2 亿美元的 C 轮融资,估值 10 亿美元,由 General Catalyst 与专注机器人的 RoboStrategy 领投,客户包括 NASA、Amazon 与 Lockheed Martin。技术取向上联合创始人兼 CEO Evan Beard 与 AI 负责人 Leif Jentoft 说得很明确:有一个共享基座模型,客户通过演示与微调去适配;最大模型参数量在低数十亿这一档,按前沿实验室标准并不算大;「数据质量远比原始数量重要」,边缘个案靠几十例现场干预就能修好。落地方式是把职责切开——机器上下料用一套零样本感知系统负责找与认零件,运动控制与单元逻辑仍走传统编程;感知的骨干在超过十亿张图像上训练,因而能区分光照、材质与前景背景。推理刻意放在本地:边缘 GPU 处理腕部相机与传感器数据、生成「动作块」再流向底层控制,因为多数工厂与仓库没有可靠网络、停机时间直接影响客户验收。他们也承认仿真不是万能的——涉及液体、吸附、切割柔性材料的任务当前难以复现,因此生产失败信号与人工纠正也被回收用于改进。平台侧 StandardOS 开放 API 与 SDK 供外部开发者自建机器人应用,文中提到 NVIDIA Cosmos 这类世界模型可作为其上的模型选项。
推荐理由
把「物理 AI 难在部署不在模型」讲成了可抄的工程清单(本地推理、职责切分、几十例修边缘个案),对做机器人的团队有直接迁移价值。
主体与标签
正文
When you think of robotics and AI, you probably first think of full humanoid robots like Figure’s AI-powered machines and 1X’s NEO home robots . Those may well be the future, but arguably more important in 2026 is industrial robots — which are typically not humanoids.
Standard Bots claims to be “America’s largest AI-native industrial robot manufacturer.” It recently raised $200 million at a $1 billion valuation, in a series C round led by General Catalyst and RoboStrategy, a fund focused on robotics. Its customers include NASA, Amazon and Lockheed Martin.
We spoke to Evan Beard , co-founder and CEO, and Leif Jentoft , Head of AI, to find out more about Standard Bots’ AI stack and how its models work.
To set the scene, Standard Bots’ industrial robot arms are designed for tasks such as machine tending, welding, and assembly. Here’s a quick demo by Jentoft:
Pretrained models and task-specific adaptation
According to Beard, Standard Bots has a shared base model that customers adapt through demonstrations and fine-tuning. Jentoft added that Standard Bots runs a range of models , including a zero-shot perception system for machine tending.
Beard says its largest model is in the low billions of parameters — so it’s not that large by frontier lab standards.
“We believe data quality matters far more than raw volume,” said Jentoft, “and we focus on getting the most out of targeted data rather than chasing the largest possible dataset.” (This matches the “bitterest lesson” of Jev creator Diogo Almeida , who told us recently that the right task and the right data can matter more than compute.)
“Our market access gives us unique access to the highest value data,” he added. “ In-situ interventions can fix an edge case with a few dozen examples.”
Beard notes that Standard Bots focuses on short-horizon tasks to meet production requirements for cycle time and reliability. The company uses conventional programming for parts of a workflow that don’t require learned behavior.
Model training happens in the cloud but inference runs locally , said Beard.
What does the model do exactly?
I asked Jentoft what the learned model does in a typical robot routine, and which parts of the workflow use conventional programming?
As an example, he brought up its machine-tending solution for high-mix manufacturing.
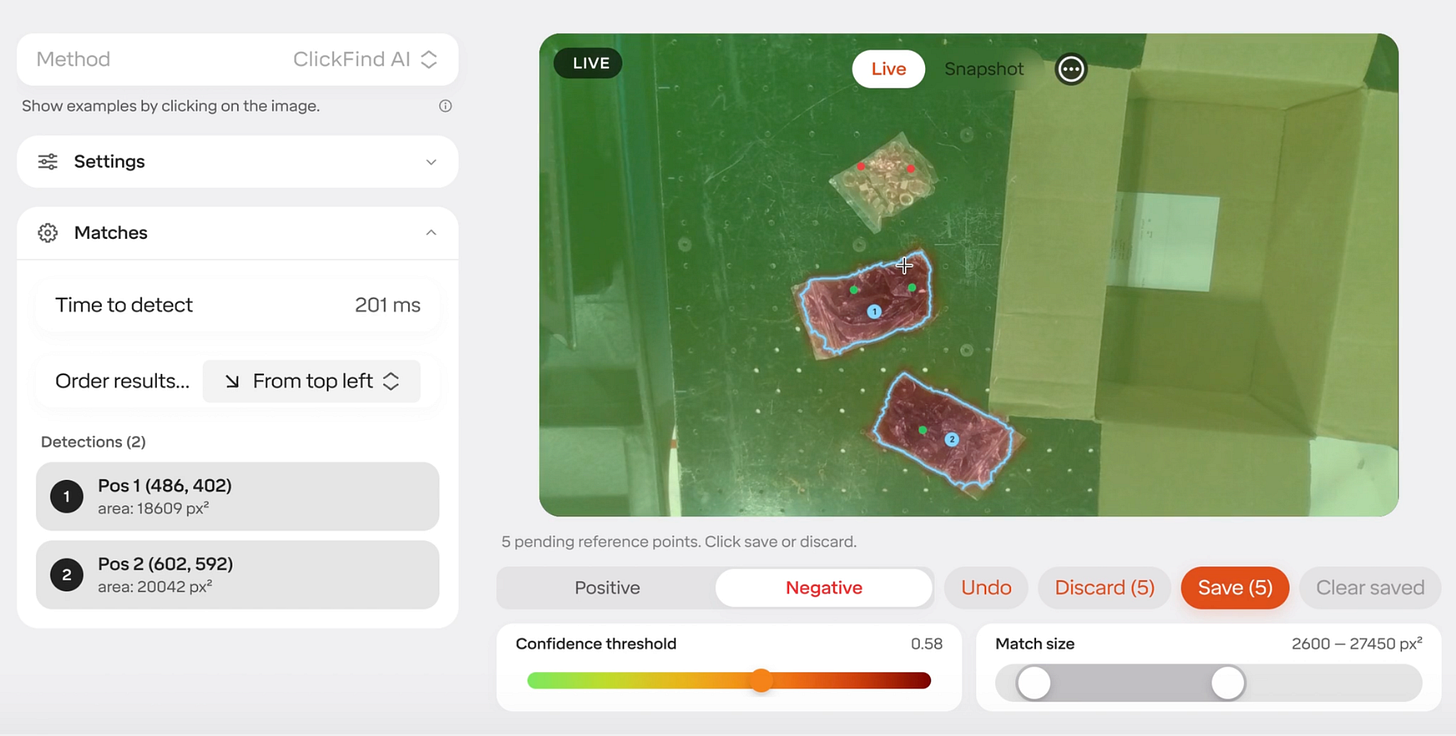
“We’ve built a zero-shot system that lets a user tell the robot which parts to look for on a given task. The model handles perception — locating and identifying the parts — while conventional programming handles the motion and the cell logic around it.”
Here’s a demonstration of the machine-tending:
“Our backbone for this task is trained on over a billion images , which is what lets the robot distinguish between lighting conditions, material types, and an object versus its background,” Jentoft said.
The Full AI Stack
Back in April, we had Applied Intuition on the podcast to talk about “Physical AI” and how it differs from on-screen AI. One of the learnings was that the Physical AI isn’t just constrained by model intelligence: the hard part is deploying models onto real hardware , under safety, latency, power, cost, and reliability constraints.
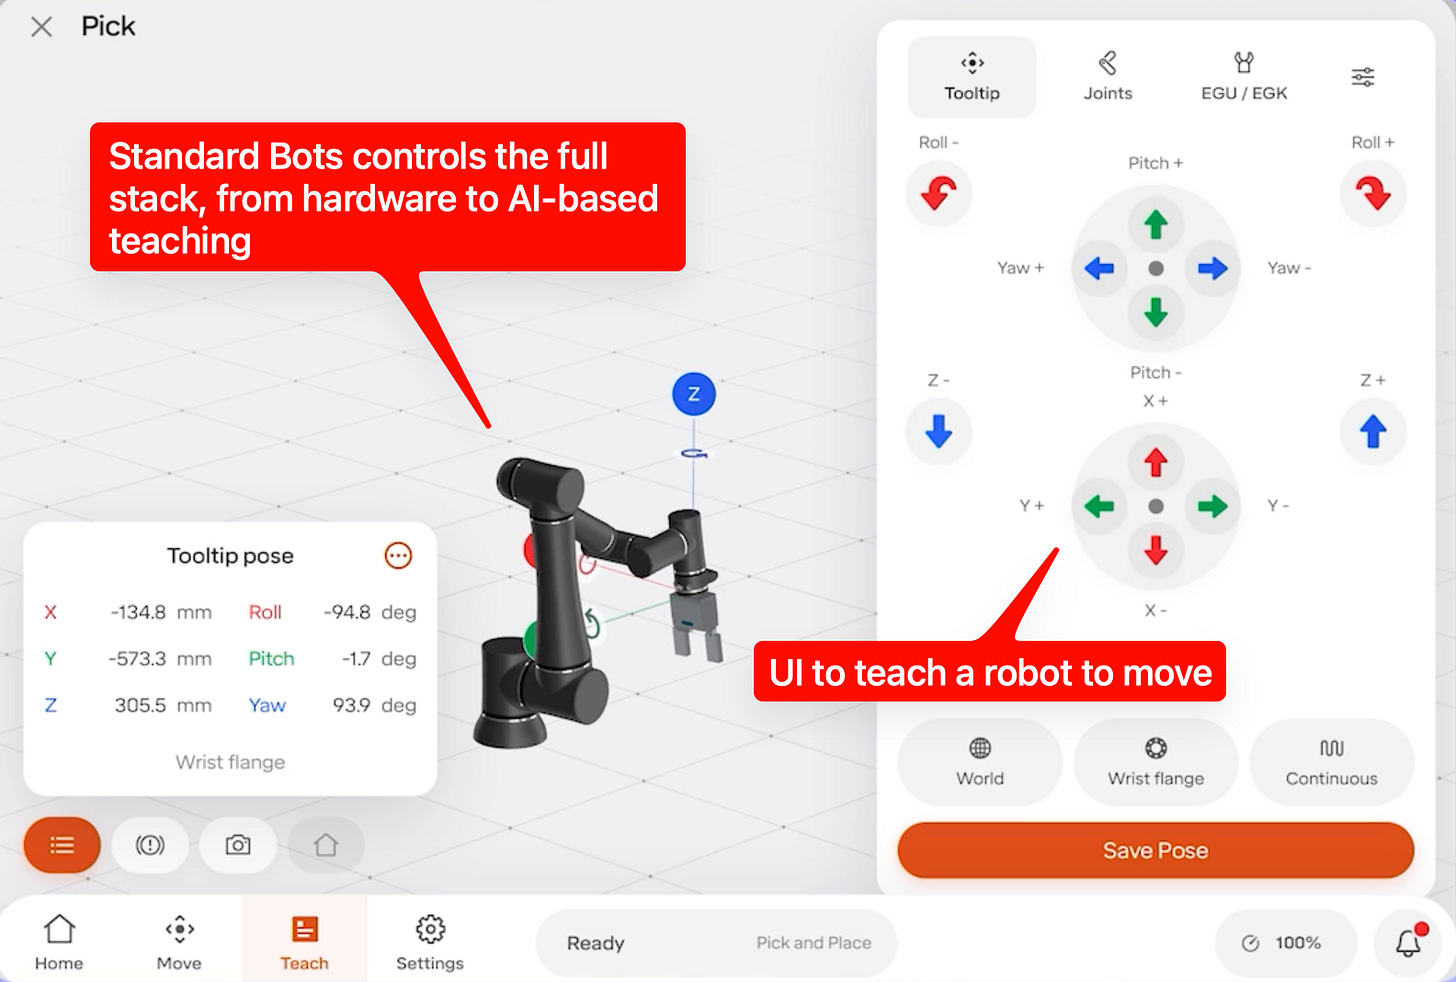
But for Standard Bots, that can also be a strength, since it controls the “full stack” from software to hardware. Jentoft points out that it controls the robotic arm, end effector, control system, and AI.
“That lets us co-optimize the models and the control policies ,” he said. “Despite claims elsewhere, no model today is truly hardware-agnostic, and co-optimizing low-level control and higher-level functions is a major advantage for both performance and iteration speed.”
Skild , a company aiming to build “general purpose robotic intelligence,” might quibble with the hardware-agnostic claim — its goal is to achieve cross-hardware generalization .
On-prem inference: sensors, edge GPUs, and ‘action chunks’
Beard had mentioned that inference is done locally, which is especially important for its core customers: factories.
“For factories, which is most of what we’re doing right now — and certainly so much opportunity that we see there — this is something where you need to do inference on-premise ,” he said.
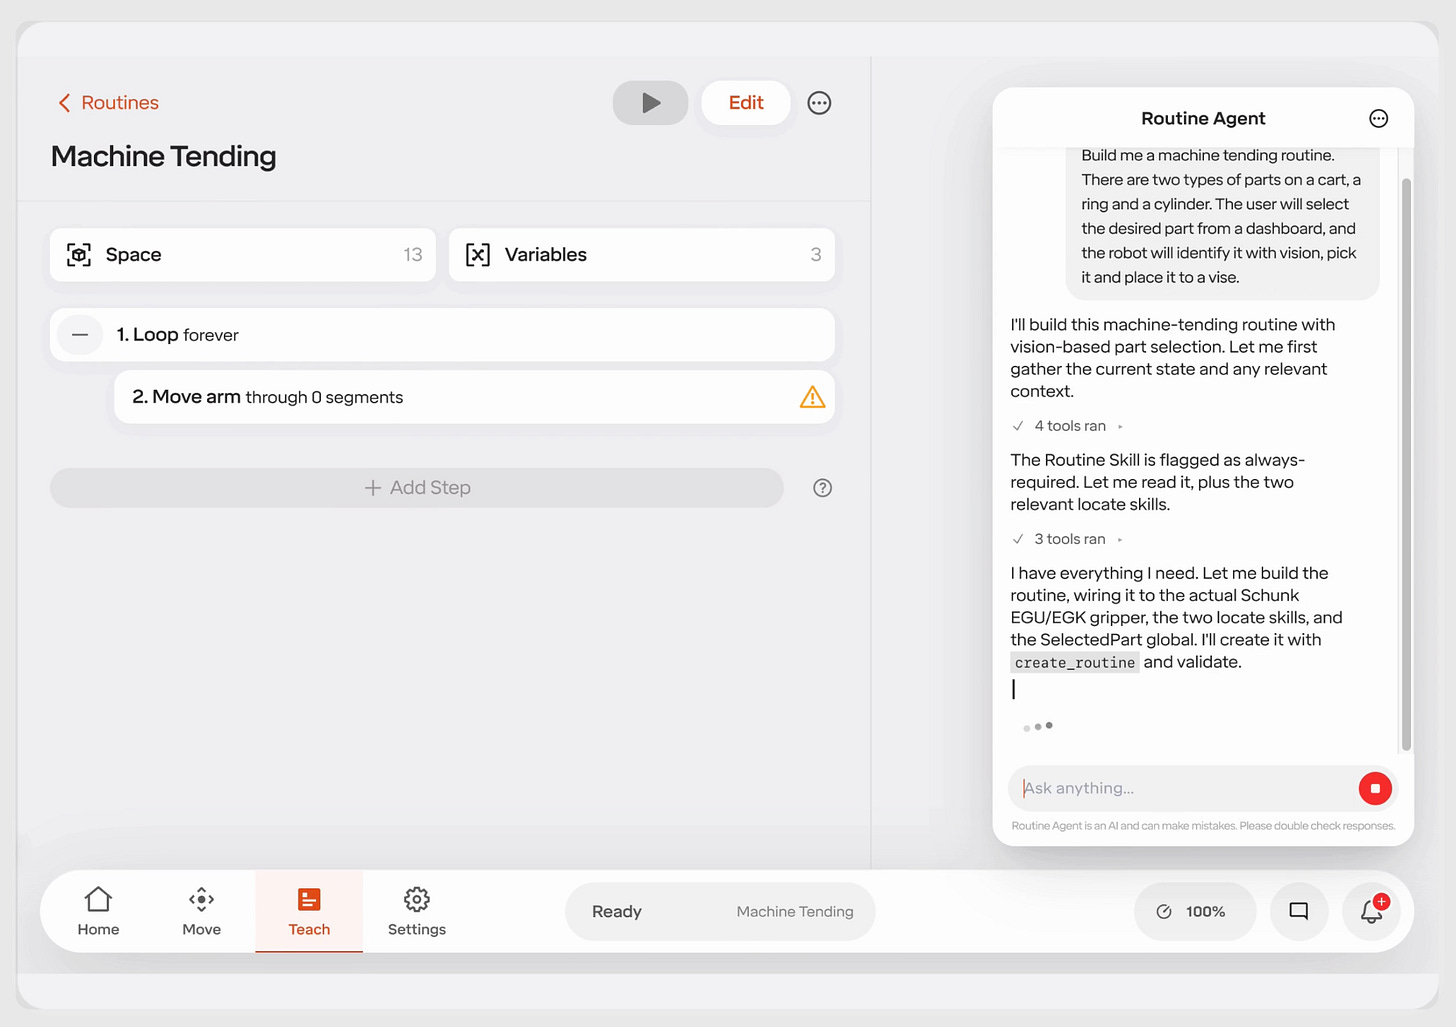
For machine tending, the model identifies parts while conventional programming handles motion. Jentoft also described how models can generate actions that feed into the robot’s control system.
“Wrist cameras and other sensors feed raw pixels and signals into the system over internal gigabit Ethernet , routed internally so no cables tangle,” he explained. “ GPUs at the edge process that data to generate action chunks , which stream to low-level control.”
He reiterated that inference is run on-premises deliberately.
“Cloud compute for robotics is operationally extremely hard — most factories and warehouses don’t have reliable internet , and that’s even more true for mobile robots. Uptime is crucial to customer acceptance, so we keep the loop local.”
Production failures and fleet learning
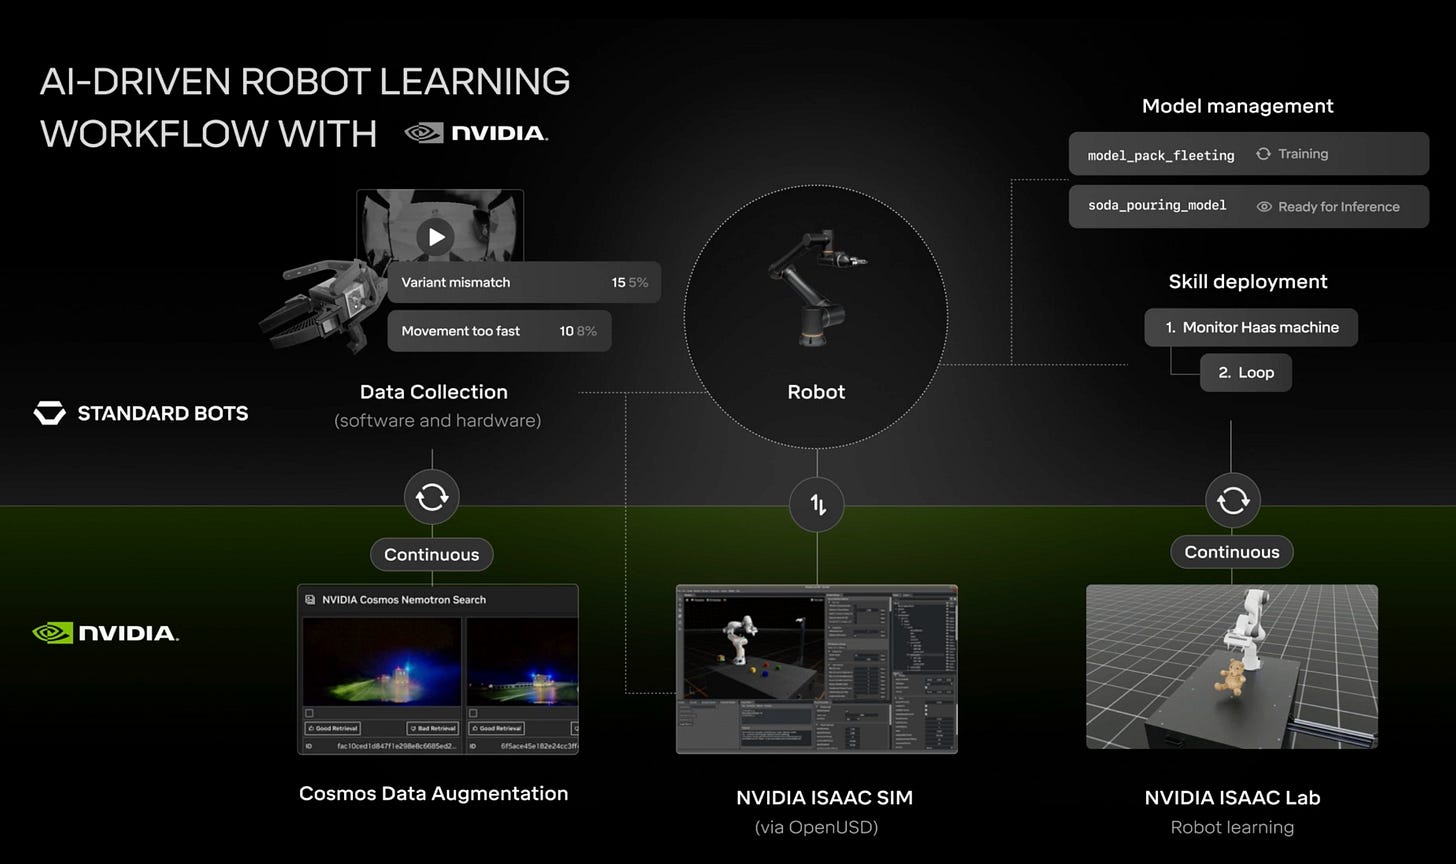
Standard Bots uses simulation where it can, but Beard says some production tasks — including those involving liquids, suction, or cutting flexible material — are difficult to reproduce in current simulators.
Real-world demonstrations are another part of the learning process. Here’s a demo of teaching a robot using a handheld touch device:
So how does it deal with failure in a robot task, and do those kinds of learnings flow back to the model?
“We capture failure signals and human corrections from deployments, and how we use that data depends on the customer,” Jentoft replied.
He noted that many of its defense customers “deploy in air-gapped environments, where nothing comes back.” But for customers that aren’t air-gapped, “fleet learning delivers enough benefit to their own applications that we typically don’t see pushback on contributing data in exchange for that performance.”
StandardOS: an AI robotics dev platform
Standard Bots has already expanded its platform so that external developers can use it. With StandardOS , it offers a set of APIs and SDKs.
According to Beard, developers can use Standard Bots’ APIs to build robotics applications with whichever parts of its stack they need, including bringing their own models. He cited NVIDIA Cosmos , an open family of omnimodal world models for physical AI, as an example ( version 3 was released late-May ).
Today, this requires developers to write their own integration code. But Standard Bots plans to make collecting data, training models, and deploying them onto its robots easier.
Focus on targeted data
Standard Bots isn’t the sexiest robotics company out there, but it is already being deployed for industrial automation at NASA, Amazon, Lockheed Martin, and others.
For AI engineers, perhaps the most useful lesson is how Standard Bots adapts AI to a specific job. It keeps the model’s role focused and uses corrections from real deployments to fix edge cases. You can, of course, apply that same approach to software agents.
As Jentoft said — and it was a recent lesson from Jev too — it’s all about “getting the most out of targeted data rather than chasing the largest possible dataset.”